From 2022 to 2025 I was a Roboticist III (Research Scientist) at the RAI Institute, formerly the Boston Dynamics AI Institute, in Cambridge, MA. I was a founding member of the Ultra Mobility Vehicle (UMV) team, responsible for system design, mechatronics, and dynamic behaviors.
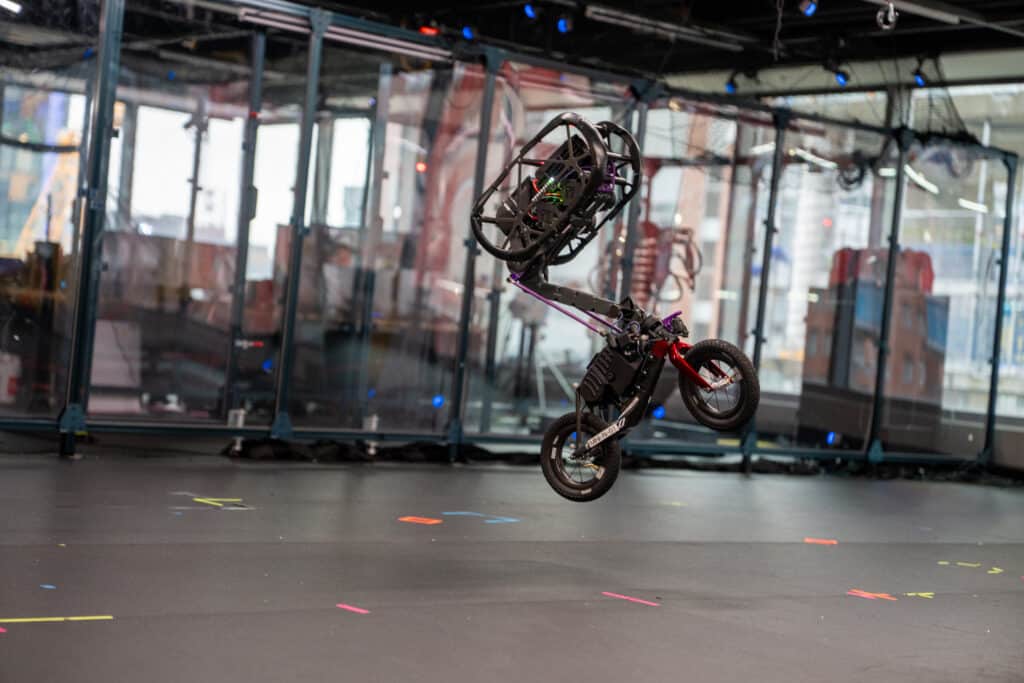
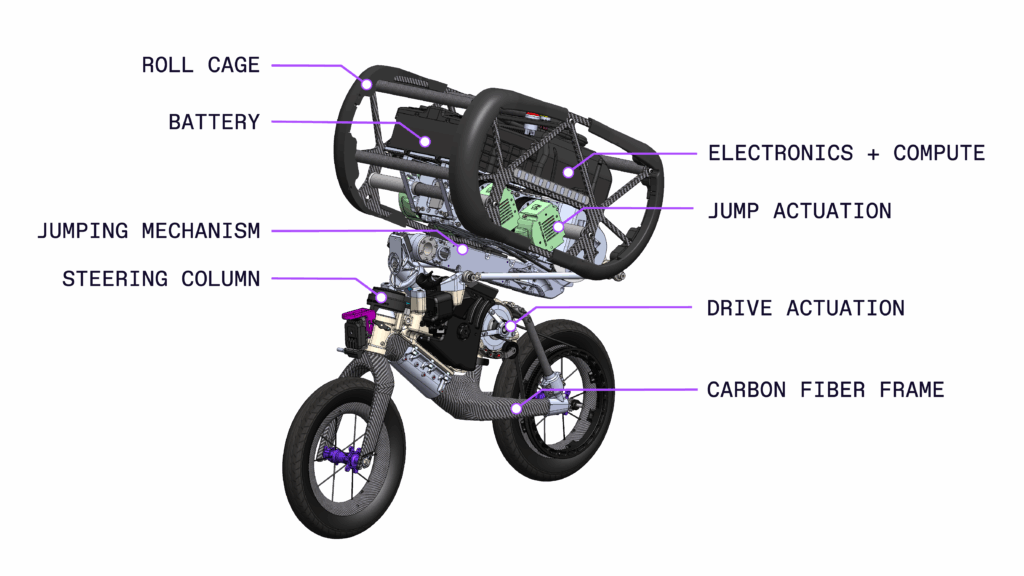
UMV is a 23.5 kg “parkour bicycle”: a bicycle chassis paired with an articulated reaction mass, so it can drive, balance, and jump with very few actuated degrees of freedom. It can track-stand, wheelie, hop on its rear wheel, front flip, drive at 8 m/s, and jump onto obstacles 1 m tall. The design has no reaction wheels or kickstands. Compute and learned control unlock what the mechanism can do.
My Role
- Led the initial system architecture study for the roughly 20-person UMV team.
- Paired robot design, mechatronic control, and reinforcement learning-based control to create highly dynamic behaviors.
- Led a 6-person team exploring reinforcement learning and optimization-based control behaviors, including obstacle avoidance.
Paper and Blog
- B. Bokser, D. J. Gonzalez, A. Preston, et al., “System Design of the Ultra Mobility Vehicle: A Driving, Balancing, and Jumping Bicycle Robot,” submitted to Science Robotics, 2026.
- RAI Institute blog: Designing Wheeled Robotic Systems for Ultra Mobility and Performance
Videos
Left: Balance and Brains, Building an Ultra Mobile Vehicle. Right: UMV Expands Mobility Repertoire.
UMV’s Latest Tricks: Kip Jump, Flip, and an Ultra Smooth Landing.
It Takes Two to Tango (ICRA 2023)
For our booth at ICRA 2023, I choreographed this two-Spot Tango dance that ran continuously! We even performed it on the main stage during Marc Raibert’s keynote speech.