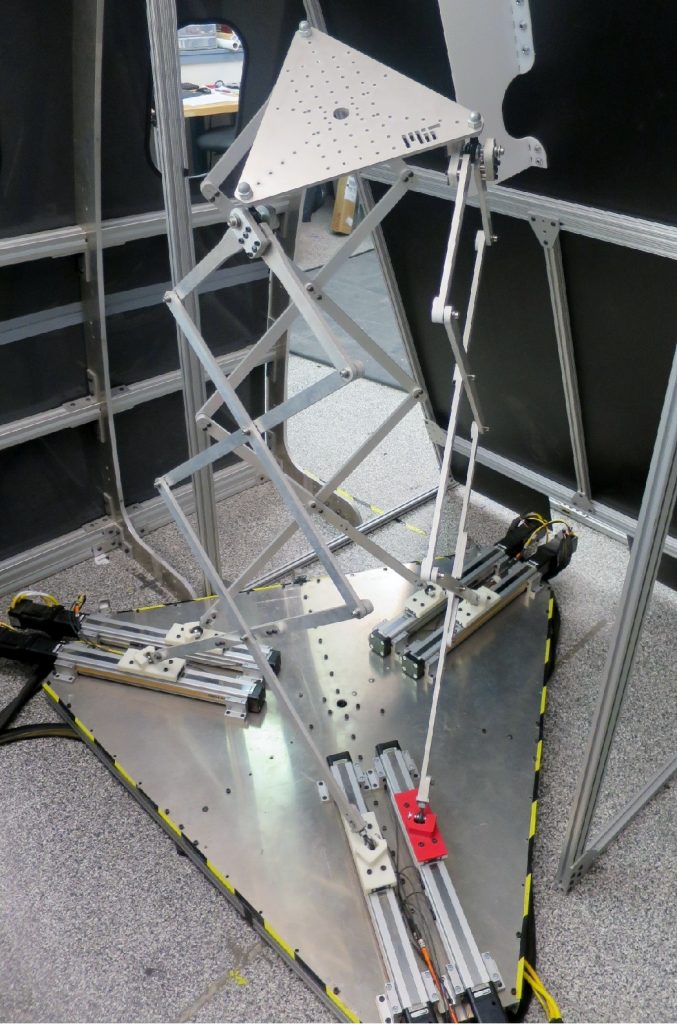
To give commercial aircraft assembly a lightweight, versatile way to install fasteners on high ceilings, I developed the Triple Scissor Extender (TSE), a 6-DOF robotic mechanism for reaching high ceilings and positioning an end effector. Three scissor mechanisms support the end effector and extend toward the ceiling, driven by six independent linear actuators that move the base ends of the scissors. The top of each scissor connects to a ball joint at one of the three corners of the triangular plate holding the end effector.
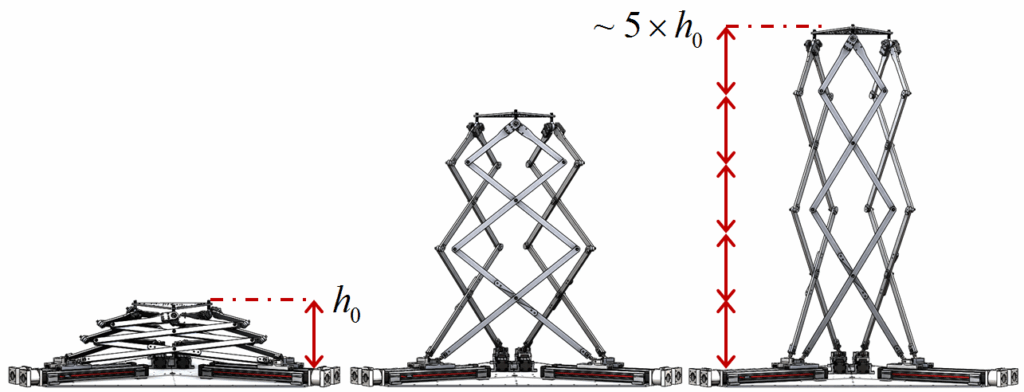
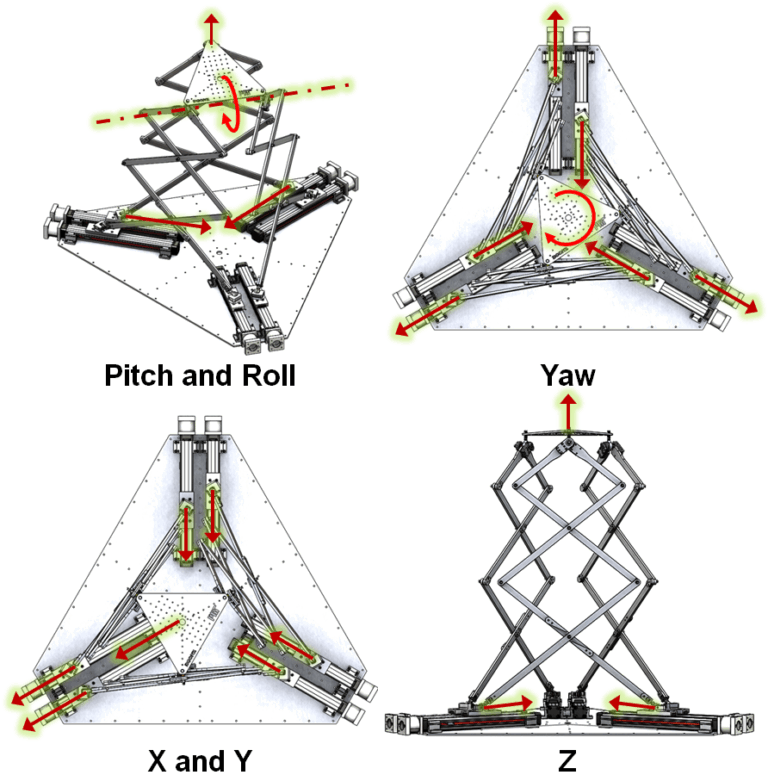
Fully contracted, the TSE is compact and easy to transport. Fully extended, it is many times its original height, like a 1-DOF aerial scissor lift, so it can reach high ceilings and walls. The scissor mechanisms give the TSE a much larger height range than most 6-DOF parallel robots that use piston-like actuators, and coordinated motion of the six base actuators lets the end effector reach an arbitrary position with an arbitrary orientation.
Publications
- D. J. Gonzalez and H. H. Asada, “Design and Analysis of 6-DOF Triple Scissor Extender Robots with Applications in Aircraft Assembly,” IEEE Robotics and Automation Letters, vol. 2, no. 3, pp. 1420-1427, 2017. Also presented at ICRA 2017. [arXiv]
- D. J. Gonzalez and H. H. Asada, “Triple Scissor Extender: A 6-DOF Lifting and Positioning Robot,” ICRA 2016, Stockholm, Sweden, pp. 847-853. [arXiv]
This work was sponsored by The Boeing Company.