West Point XE401/402: Integrated System Design Capstone
Autonomous Urban Navigation, 2019 to 2021
2nd Place, 2021 Intelligent Ground Vehicle Competition (IGVC)
Winner, 2020 EECS Department Best Project Award
Winner, 2020 EECS Department Best Final Presentation Award
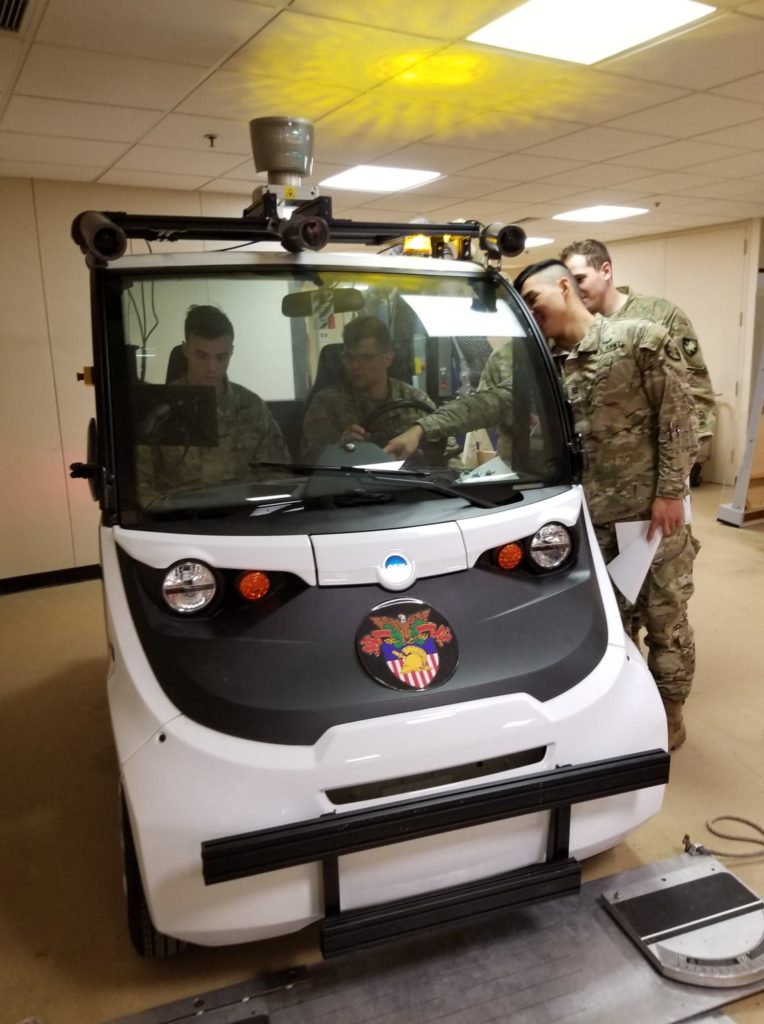
I was the lead technical instructor for the self-driving section of the senior Integrated System Design Capstone. Students added on-road driving to the Robotic Technology Kernel (RTK), a set of autonomy tools for U.S. Army ground vehicles originally designed for unstructured open terrain. Following traffic laws in an urban setting lets autonomous Army vehicles make deliveries or move personnel around cities and bases.
Students learned design and software project management while building and testing modules for lane detection, lane following, lane changes, sign and obstacle detection, stopping, and turns at intersections, then integrated them with a safety system into a custom ROS architecture.
MIT 2.12/2.120: Introduction to Robotics
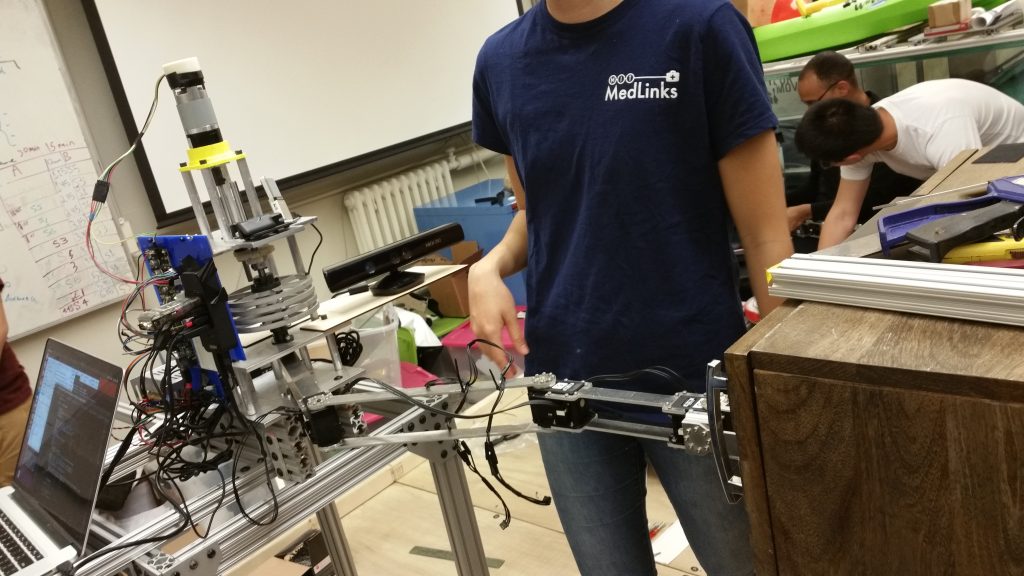
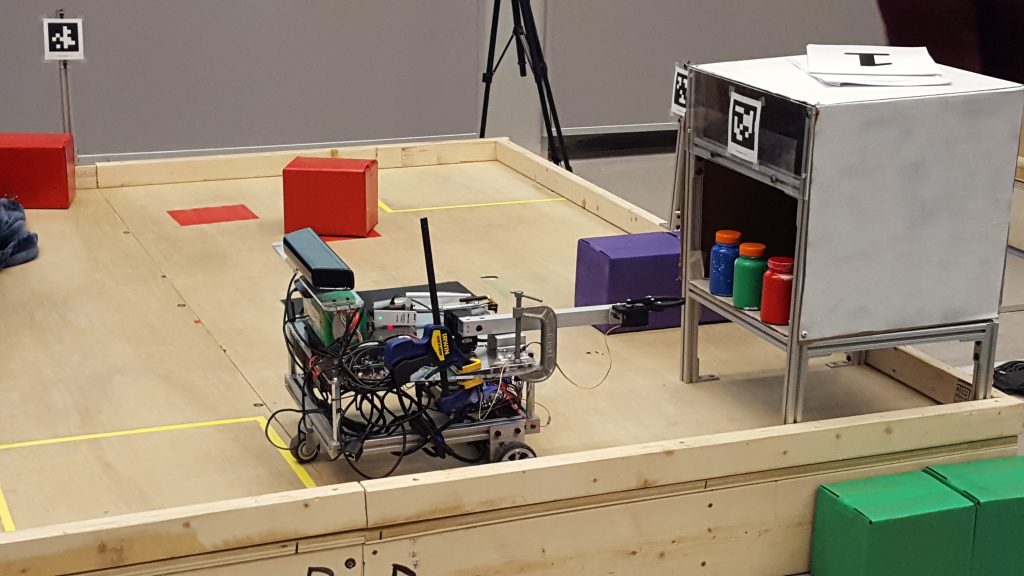
Students in 2.12 learn a breadth of general robotics knowledge and a depth of fundamental kinematics, dynamics, force interaction, design, and feedback control for mobile and manipulator robots. Beyond lectures and problem sets, the class has a major lab component and a team final project that ends in a competition, with a new theme each year.
- Pizza Making and Delivering Robots, Spring 2019: Laboratory Instructor on Record with Prof. Harry Asada. I led the TAs and lab assistants, and organized the design and assembly of a delta robot for the final project: robots that assemble and deliver pizzas to restaurant patrons.
- Series Elastic Actuators and Collaborative Robots, Fall 2017: Classroom Teaching Assistant with Profs. Harry Asada and Kamal Youcef-Toumi. I taught recitations, office hours, and exam reviews, and advised teams building series elastic actuator collaborative robots that help users with physical disabilities.
- Laboratory Mobile Robot Redesign, Summer 2015: I redesigned the lab hardware, software, and assignments for mobile robots and computer vision to reflect modern techniques. The labs have been used every year since.
- Soccer Kicker and Goalie Robots, Fall 2014: Head Teaching Assistant. I built a high-speed computer vision system and network that tracked soccer balls and relayed their positions to every team in real time, and wrote the base communication and actuator code in C++, Python, and MATLAB.