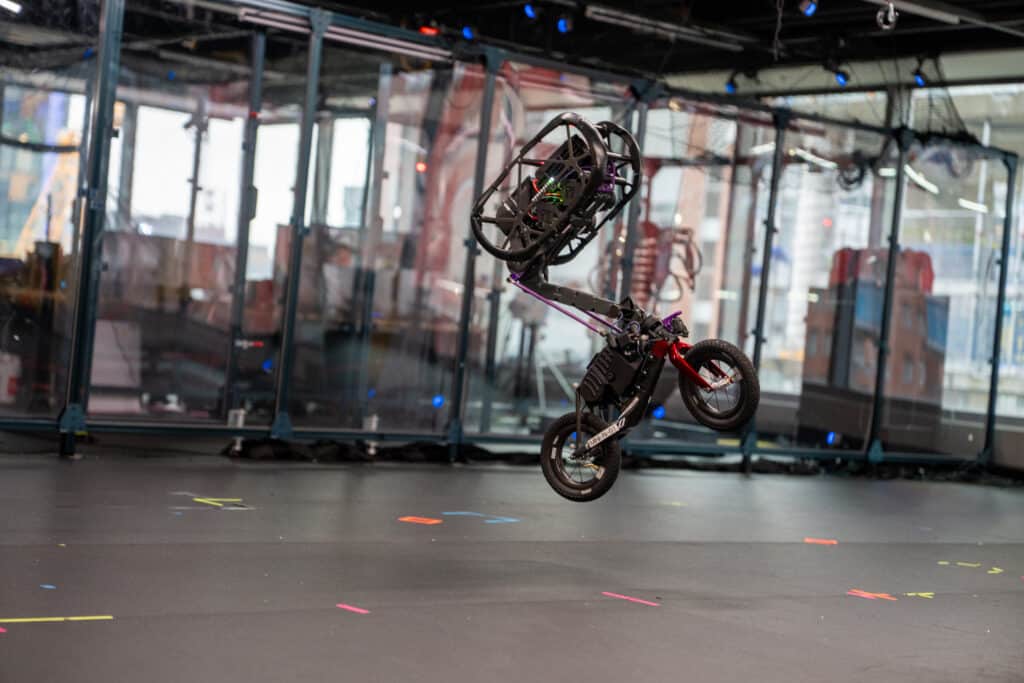
October 2026: I am proud to announce that my team’s journal article on the System Design of the Ultra Mobility Vehicle robotic bicycle has been published in Science Robotics!
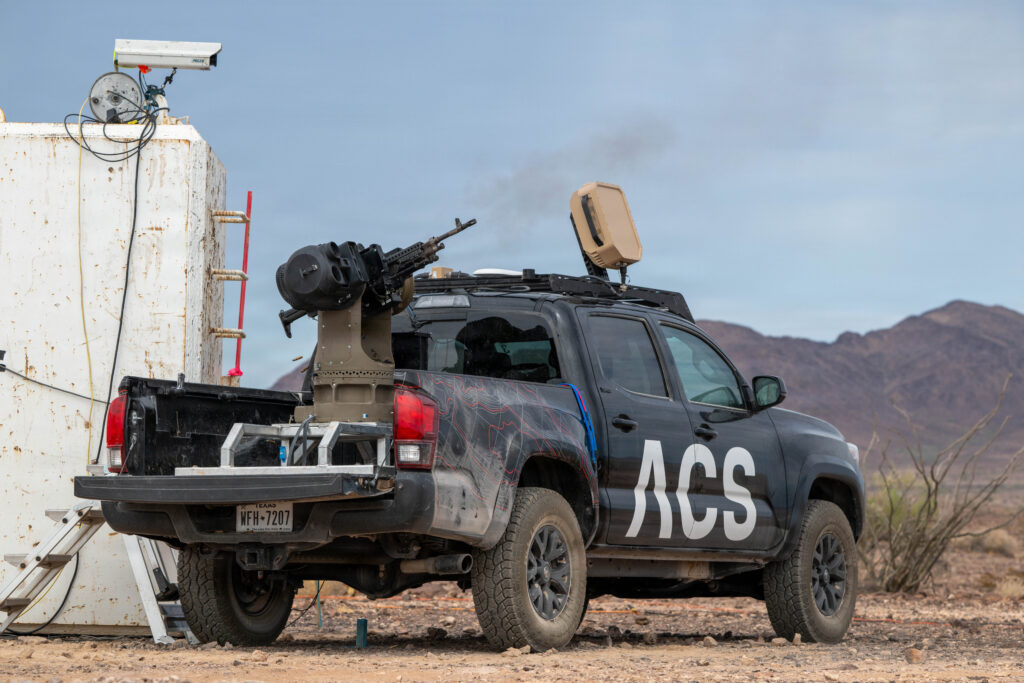
I’m a roboticist who builds dynamic robots and gets them working in the field. I lead Robotics and System Integration at the Allen Control Systems Innovation Lab in Austin, TX, where I prototype, integrate, and field test new sensors, platforms, and capabilities for Bullfrog, an autonomous counter-drone robotic weapon system.
Before ACS, I was a founding member of the Ultra Mobility Vehicle team at the RAI Institute (formerly the Boston Dynamics AI Institute), a Robotics Research Engineer at Aurora Flight Sciences working on counter-UAS state estimation and a DARPA adaptive control program, and an Army Research Laboratory Postdoctoral Fellow at West Point. I earned my Ph.D., S.M., and S.B. in Mechanical Engineering at MIT with Prof. Harry Asada.
My strengths are dynamics, controls, state estimation, and sensor fusion, and turning those into hardware that works outside the lab. I like hard integration problems: new sensors, new platforms, tight timelines, and a demo at the end.
Recent Work
- Allen Control Systems (2025 to present): Bullfrog counter-drone integrations with radars, ground and maritime platforms, and partner systems, fielded at Falcon Peak 26.2 and the U.S. Army’s Operation Jailbreak.
- RAI Institute (2022 to 2025): Ultra Mobility Vehicle, a jumping, flipping bicycle robot controlled with reinforcement learning, published in Science Robotics, plus a robot tango for ICRA 2023.
- Aurora Flight Sciences (2021 to 2022): Target state estimation for the MIDAS counter-drone interceptor, and the winning DARPA LINC adaptive control proposal.
- BattleBots: Counter-gyro design lead for RIPperoni and motor control for Team Valkyrie.
Earlier Research
- AGRO, a hybrid wheel-leg agile ground robot (West Point)
- West Point/Purdue team at the Indy Autonomous Challenge
- Extra Robotic Legs, a wearable robot for carrying heavy PPE (MIT Ph.D.)
- Triple Scissor Extender, a 6-DOF aircraft assembly robot (MIT S.M.)
Contact
Email: dgonzrobotics {at} gmail.com
LinkedIn · Google Scholar