AGRO is a novel Agile Ground RObot that combines the best attributes of legged and wheeled platforms to be highly maneuverable and rapidly deployable in emergency situations. The AGRO Mk I prototype has a four-wheel independent drive and steering (4WIDS) architecture that lets it maneuver quasi-omnidirectionally on the ground.


This wheel architecture also lets AGRO control its orientation in the air and land on its “feet” like a cat. Just as a cat twists its body and legs while conserving angular momentum, AGRO uses the reaction torques from its in-wheel hub motors to control its body orientation mid-air, land upright, and spread the impact evenly across all four wheels. That means emergency responders can deploy it quickly by throwing it over walls and fences or through windows, without the risk of landing upside down or overloading the suspension. IEEE Spectrum covered our initial results here.
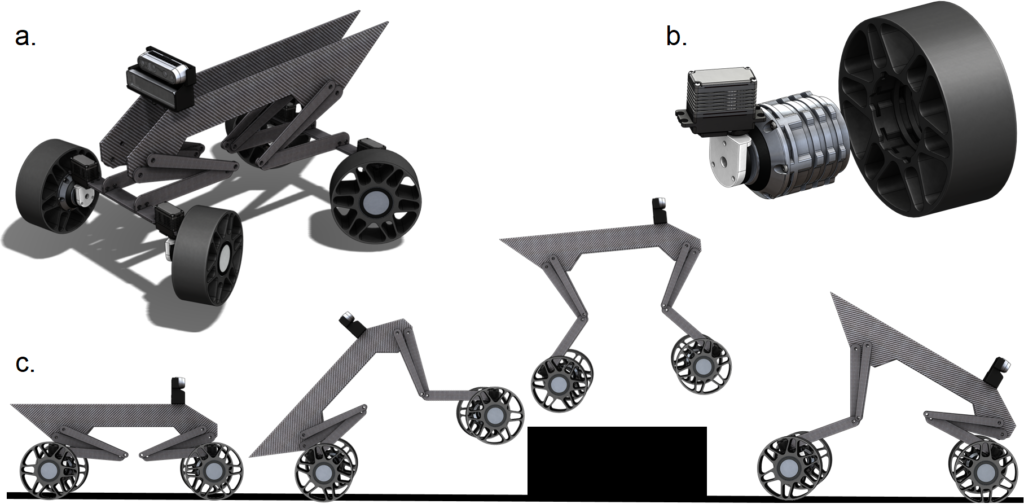
Next steps for AGRO included (b) non-pneumatic tires to absorb landing impacts, context-dependent dynamic motion primitives to (c) hop up stairs or onto curbs, and semiautonomous teleoperation to prevent rollovers or crashes during high-speed maneuvering.
Publications
- J. Kim, D. J. Gonzalez, and C. M. Korpela, “Comparing Feedback Linearization and Backstepping Control for Airborne Orientation of Agile Ground Robots using Wheel Reaction Torque,” 2021 American Control Conference (ACC 2021), New Orleans, LA, May 2021.
- A. H. Rodriguez, D. J. Gonzalez, and M. C. Lesak, “Design of a Printed Circuit Board (PCB) for Electrical Integration on the Agile Ground Robot (AGRO),” IEEE MIT Undergraduate Research and Technology Conference (URTC 2020), Cambridge, MA, October 2020.
- D. J. Gonzalez, M. C. Lesak, A. H. Rodriguez, J. A. Cymerman, and C. M. Korpela, “Dynamics and Aerial Attitude Control for Rapid Emergency Deployment of the Four-Wheel Independent Drive and Steering (4WIDS) Agile Ground Robot AGRO,” IROS 2020, Las Vegas, NV, October 2020.
- D. J. Gonzalez and C. M. Korpela, “Novel Ideas for Hybrid Wheel-Leg Robots with AGRO (the Agile Ground RObot),” Workshop on Real-world Deployment of Legged Robots, ICRA 2020.