I joined Allen Control Systems in September 2025 as about employee #70. ACS builds Bullfrog, an autonomous counter-drone robotic weapon system that detects, tracks, and engages small drones. I started as Robotics Systems Lead and now lead Robotics and System Integration at the ACS Innovation Lab, where I prototype, integrate, and field test new capabilities, sensors, and platforms for Bullfrog.
Innovation Lab Lead (Robotics & System Integration), 2026 to present
- Integrated third-party sensors and seven partner platforms (three ground vehicles and four uncrewed surface vessels) with Bullfrog for on-the-move target cueing and tracking.
- Led cross-functional integration teams of electrical, software, controls, and operations engineers, together with partner-company engineers.
- Company-wide technical point of contact for third-party integrations with Bullfrog.
- Led the Bullfrog laser dazzler integration demo for non-kinetic drone defeat.
Falcon Peak 26.2
ACS was one of 20 industry participants at Falcon Peak 26.2, a U.S. Northern Command and Joint Interagency Task Force 401 counter-drone experiment at Yuma Proving Ground. I integrated the Echodyne EchoShield radar with Bullfrog for target cueing and tracking, and supported live-fire testing of other partner integrations.
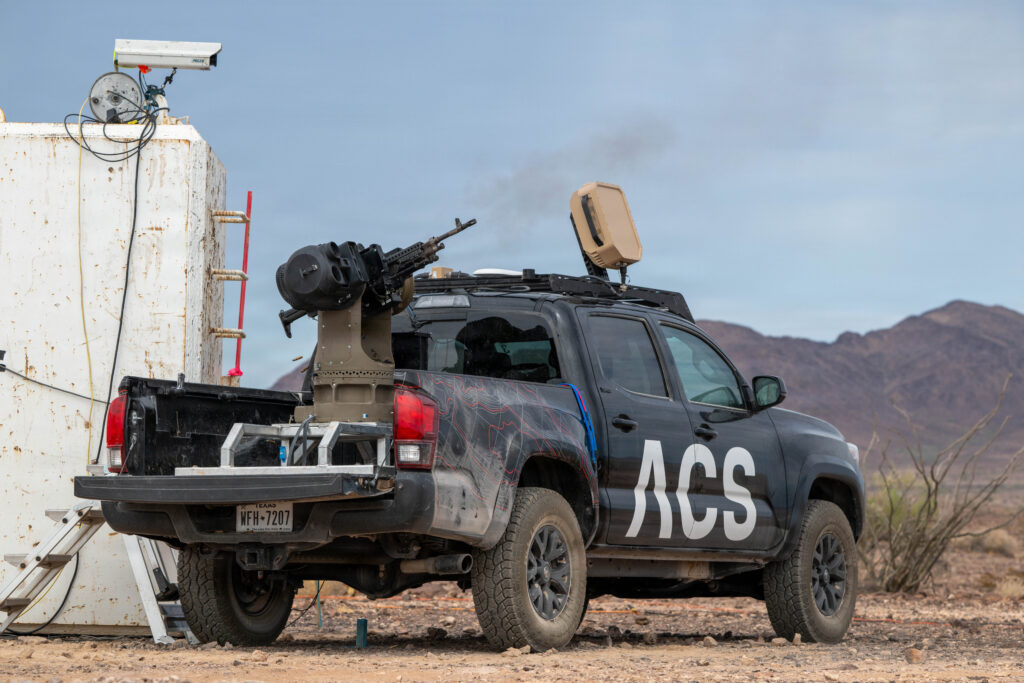
Falcon Peak B-roll from DVIDS, with Bullfrog footage at the start.
U.S. Army Operation Jailbreak
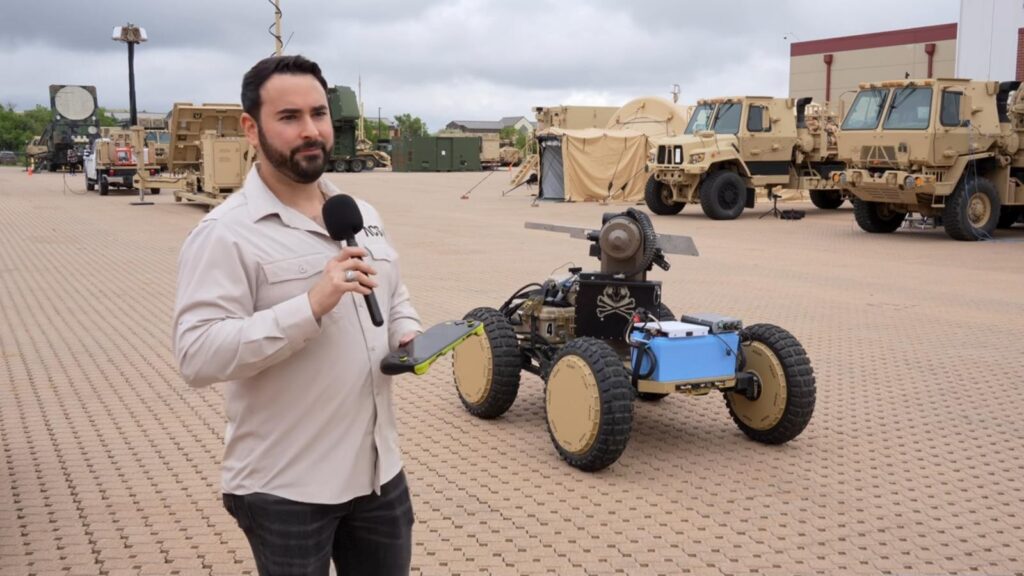
At Operation Jailbreak, engineers from dozens of companies integrated their systems in days rather than years. Our team mounted Bullfrog on an AZAK ground robot, cued by a Leonardo DRS radar on a companion vehicle, networked with Picogrid, tasked through Anduril Lattice, and driven by HavocAI autonomy. Watch my interview walking through the integration.
Laser Dazzler
Kinetic defeat doesn’t always make sense in dense or sensitive environments. I led the integration demo of a laser dazzler on Bullfrog, which uses the turret’s aiming to degrade an adversary drone’s optics.
Robotics Systems Lead (Staff Engineer), 2025 to 2026
Led the Robotics Systems Team, making sure Bullfrog’s mechanical design, electronics, controls, and computer vision subsystems work together as one high-performance dynamic robot. Architected next-generation on-the-move stabilization control, improved EKF-based target tracking, and developed a test target telemetry system for computer vision data collection.