
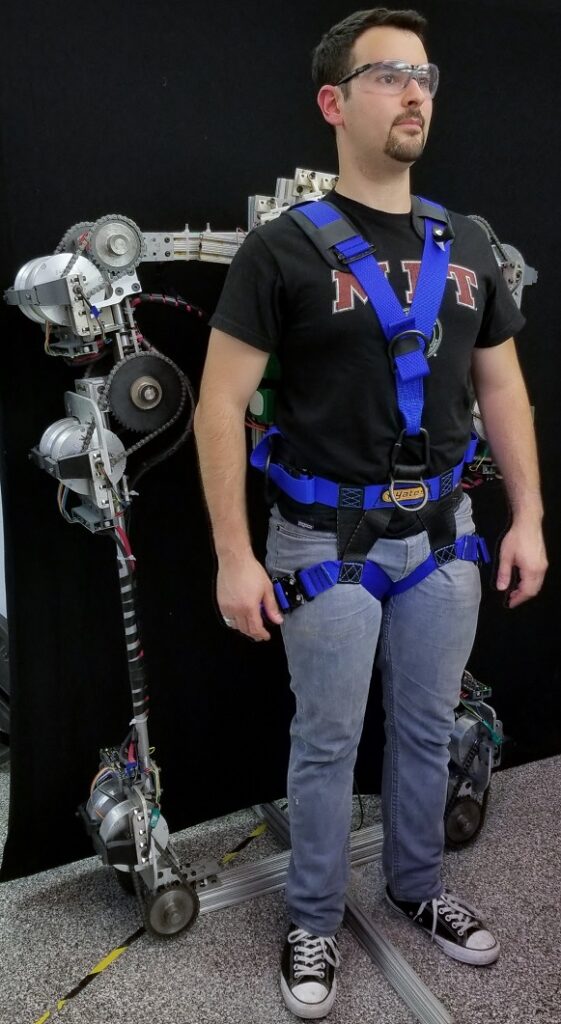
The Extra Robotic Legs (XRL) system is a robotic augmentation worn by a human operator: two articulated robot legs that help carry a heavy backpack payload and part of the operator’s own weight. The design was driven by the need to make Department of Energy hazardous material emergency responders more effective while they are weighed down by their personal protective equipment.
Essentially a backpack with legs, the XRL system must bear large loads, but it also needs a proprioceptive transmission for close physical interaction with the operator. The linkage and actuator design minimizes the peak actuator torque by exploiting torque redistribution through a closed kinematic chain. I built a prototype using insights from force analyses and human-robot interaction safety requirements.
A seamless hybrid control architecture lets the operator command the pace of the stand-to-squat transition. The failsafe hybrid open-loop/closed-loop controller splits Cartesian space into a closed-loop subspace, where the robot controls its own balance and stability, and an open-loop subspace, where the operator moves the robot at will through force interaction alone. Distributing control to the joint level wherever possible makes the system robust to disconnections from the central computer.

The human-XRL quadruped walks best with an ambling gait in which the rear legs lead the front legs by 25% of the gait period, which minimizes energy lost to foot impacts while maximizing the margin of balance. Unlike a quadruped robot, the XRL cannot command the human’s limbs. By modeling the human-robot system during steady walking as a coupled pair of nonlinear limit cycle oscillators, I showed that a coupling made only of passive mechanical components can produce a stable limit cycle that synchronizes the gaits, and that active control can further improve stability and the rate of synchronization.
Publications
- D. J. Gonzalez and H. H. Asada, “Passive Quadrupedal Gait Synchronization for Extra Robotic Legs Using a Dynamically Coupled Double Rimless Wheel Model,” ICRA 2020, Paris, France, May 2020.
- D. J. Gonzalez and H. H. Asada, “Hybrid Open-Loop Closed-Loop Control of Coupled Human-Robot Balance During Assisted Stance Transition with Extra Robotic Legs,” IEEE Robotics and Automation Letters, vol. 4, no. 2, pp. 1676-1683, 2019. Also presented at ICRA 2019. [arXiv]
- D. J. Gonzalez and H. H. Asada, “Extra Robotic Legs for Bearing Equipment Loads During Emergency Response,” Waste Management Symposium (WMS 2019), Phoenix, AZ, March 2019.
- D. J. Gonzalez and H. H. Asada, “Design of Extra Robotic Legs for Augmenting Human Payload Capabilities by Exploiting Singularity and Torque Redistribution,” IROS 2018, Madrid, Spain, October 2018. [arXiv]
- Patent: D. J. Gonzalez and H. H. Asada, “Wearable Robotic Systems for Supporting a Load,” U.S. Patent Application 16/020,823, 2018.
This work was sponsored by the National Science Foundation and the U.S. Department of Energy.